OYMotion logoOYMotion

ROH-A001

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-30
6 DOF
Active degrees of freedom
11
Mechanical joint count
0.54–0.55 kg
Hand weight
5
Finger count

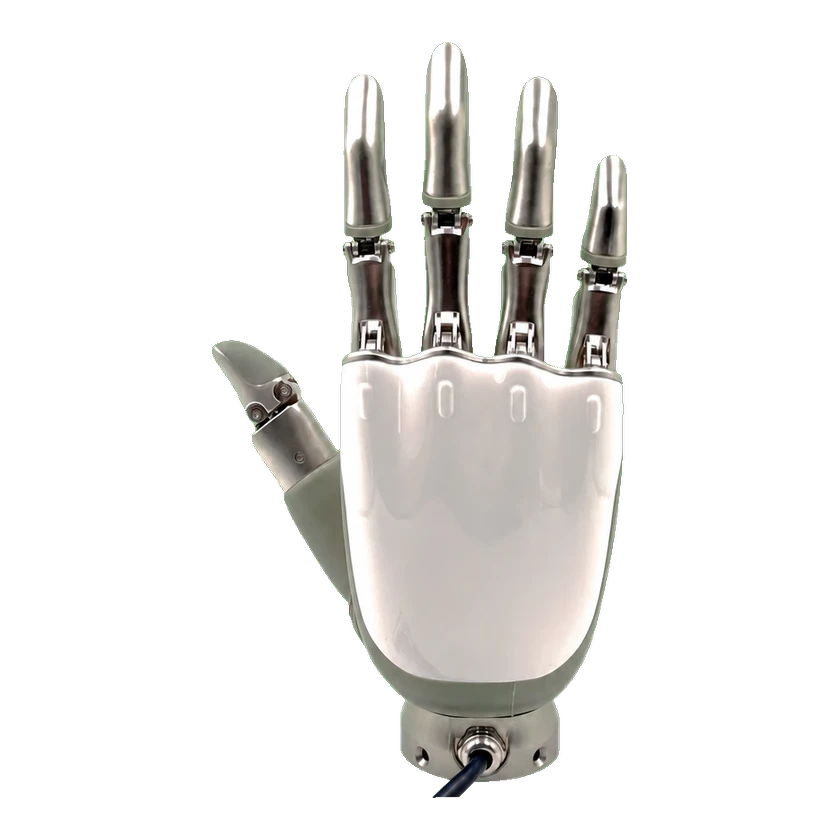
ROH-A001 is OYMotion’s five-finger dexterous robotic hand for robot end-effectors, research, and education. Its lightweight alloy structure has 11 motion joints and 6 active degrees of freedom, supports UART, RS485, and CAN, and suits grasping, manipulation, and bionic prosthetics.

1 / 1ROH-A001

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Active degrees of freedom
6 DOF

ROH-A001 V1.3.3 distinguishes eleven motion joints from six active DOF.

Ingress Protection (IP)
Not waterproof
Mechanical joint count
11

ROH-A001 V1.3.3 distinguishes eleven motion joints from six active DOF.

Materials
Aluminum alloy, zinc alloy, stainless steel, silicone, plastic
Total degrees of freedom
11 DOF
Joint Motion Range
0–31 °
Joint Motion Range
0–50 °
Joint Motion Range
0–90 °

Mobility & Payload

General Payload
30 kg

Mechanical and mounting

Dimension reference frame
Middle fingertip to wrist 184 mm; thumb tip to wrist 93 mm; thumb length 111 mm; palm width 83 mm; wrist diameter 49 mm
Length
18.4 cm
Mounting flange standard
ISO 9409-1:2004
Mounting interface
Compliant with ISO 9409-1:2004
Hand weight
0.54–0.55 kg

Including wrist; manual V1.3.3 states 545±5 g.

Width
8.3 cm

Mechanical Structure

Dexterous Hand
Five-finger dexterous hand with 11 motion joints and 6 active DOF
End-Effector
Robotic end effector
Load Cycles
5000
Operating voltage
12–24 V
Operating voltage
12–48 V
Rated power
48 W

Battery and Runtime

Power Supply
DC 12–24 V
Power Supply
DC 12–48 V

Performance and tasks

Repeatability
1 mm

Reliability and environment

Operating temperature
-10–40 °C

Interaction and Communication

Communication
UART / RS485 / CAN

Configurations

ROH-A001 — CAN interface

Communication and control

Communication interface
CAN

Interface option documented in ROH-A001 manual V1.3.3. Touchscreen operation does not establish tactile sensing.
ROH-A001 — UART interface

Communication and control

Communication interface
UART

Interface option documented in ROH-A001 manual V1.3.3. Touchscreen operation does not establish tactile sensing.

ROH-A001 — RS485 interface

Communication and control

Communication interface
RS485

Interface option documented in ROH-A001 manual V1.3.3. Touchscreen operation does not establish tactile sensing.

Commercial Status

Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction