
 mirrorme
Apollo
Price
Unknown
Type
Quadruped Robots
Applications
Industrial · Inspection & Maintenance
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Jan 22, 2026
Country/Region
China
Last Verified
2026-08-30
6 h
Runtime
0–5 m/s
Walking Speed
65 kg
Weight
67 cm
Height
Apollo is MirrorMe Technology’s industrial quadruped robot for inspection. It combines multi-sensor navigation, dynamic obstacle avoidance, 50 kg continuous walking load, 6-hour runtime, IP67 protection, and field expansion interfaces.
1 / 1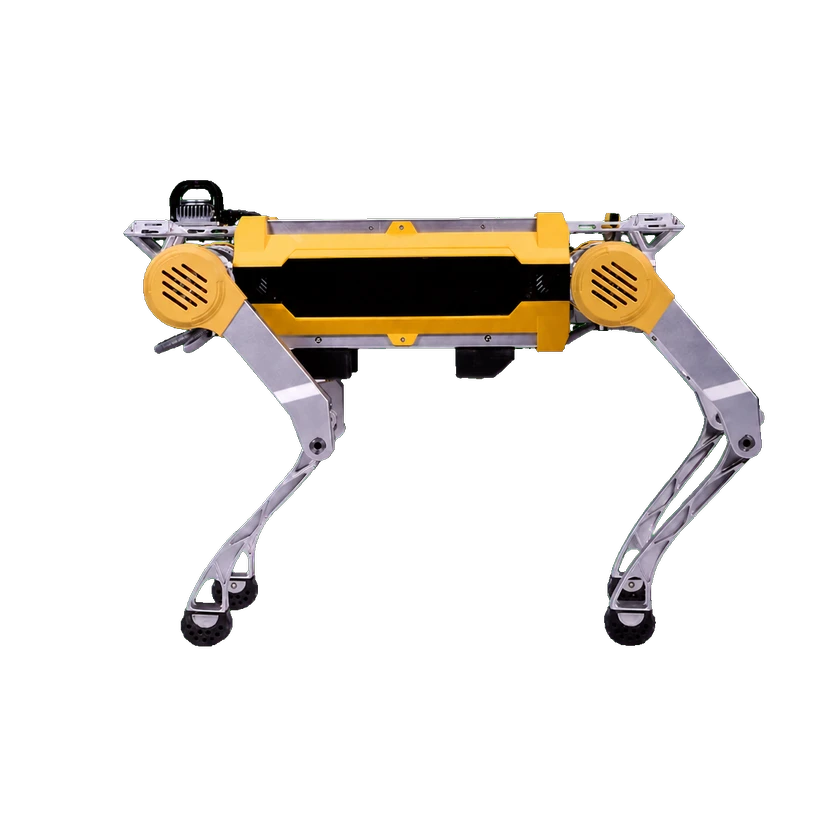
Hardware Specification
Physical Specifications
Ingress Protection (IP)
IP67
Locomotion Type
Quadruped walking
Dimensions (Standing)
108.3 cm
Dimensions (Standing)
50.7 cm
Dimensions (Standing)
67 cm
Total degrees of freedom
12 DOF
Mobility & Payload
Maximum Grade Angle
45°
Step Height
40 cm
Continuous Walking Payload
50 kg
Walking Speed
0–5 m/s
Mechanical and mounting
Height
67 cm
Weight
65 kg
Mechanical Structure
Chassis
Battery, electronic control, and motor systems are modularly independent
Sensors
LiDAR
Optional laser radar
Obstacle Avoidance
360° laser-scanning dynamic obstacle avoidance
Sensors
Various operational sensors
Vision Sensor
LiDAR optional
Battery and Runtime
Battery Capacity
2310 Wh
Battery Swap Support
Optional quick battery replacement in under 10 seconds
Charging Dock
Interface provided; hardware optional
Runtime
6 h
Compute Platform
Software Algorithm
Multi-sensor fusion positioning and navigation algorithm
Reliability and environment
Operating temperature
-20 °C to 55 °C
Interaction and Communication
External Port
4 Gigabit network ports; 1 BAT port; 1 standard Gigabit network port
Smart Navigation
Multi-sensor fusion navigation with autonomous inspection-path planning
Remote Controller
2.4 GHz remote controller and Android app
Development and Expansion
Payload Power Supply
12 V × 3 and 24 V × 3
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Jan 22, 2026
Related Entities
Timeline
- Robot releaseApollo
Submit a source or correction