
 Inspire Robots
RH56F1
Series-level record; weight, communication interface and tactile sensing vary by E2/E4 and T1 configurations.
RH56F1 · F1
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercial
Availability
On sale
Purchase
Contact manufacturer
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-14
6 DOF
Active degrees of freedom
12
Mechanical joint count
0.605–0.640 kg
Weight
5
Finger count
RH56F1 is Inspire Robots’ all-metal anthropomorphic five-finger dexterous hand for humanoid robots. It combines six active degrees of freedom, twelve joints, multimodal tactile, force, position and temperature sensing, 1 kHz real-time EtherCAT communication, 30 kg static passive load capacity and configurable RS485 or CAN FD interfaces.
1 / 1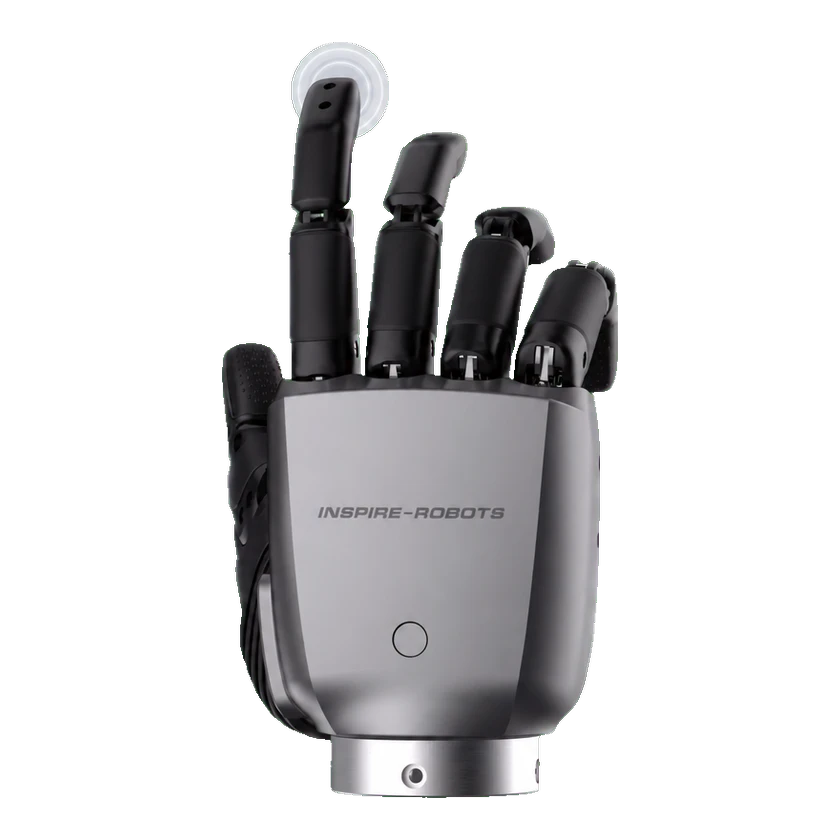
Hardware Specification
Degrees of freedom and drive
Frame Material
integrated all-metal skeleton
Active degrees of freedom
6 DOF
Mechanical joint count
12
Materials
all-metal body
Total degrees of freedom
6 DOF
Mobility & Payload
Hand Payload
30 kg
Mechanical and mounting
Mounting interface
Ø38 mm and Ø50 mm wrist mounting flanges
Weight
0.605–0.640 kg
Electrical and integration
Dexterous Hand
anthropomorphic five-finger dexterous hand
Dexterous Hand Model
RH56F1
Internal Wiring
concealed internal wiring
Joint Type
12 articulated finger joints
Operating voltage
24–48 V
Sensors
Force/Torque Sensor
force sensing with 0.1 N resolution; thumb ≥15 N and fingers ≥10 N
Sensors
24 sensor sets across tactile, force, position and temperature categories
Tactile Sensor
tactile variants: 8 sensors, 30 N range, 5% FS accuracy
Battery and Runtime
Power Supply
DC 24–48 V; peak current 5 A at 24 V
Performance and tasks
Repeatability
0.2 mm
Interaction and Communication
Communication
EtherCAT; RS485; CAN FD
External Port
EtherCAT + RS485 on E2 variants; EtherCAT + CAN FD on E4 variants
System Response Time
≤0.8 s
Tactile Feedback
tactile, force, position and temperature feedback on sensor-equipped variants
Development and Expansion
Operating Modes
multi-mode force, position and hybrid control
Commercial Status
Status
Commercial
Price
Price not disclosed
Release Date
Unknown
Related Entities
Robots related to “RH56F1”
Submit a source or correction