
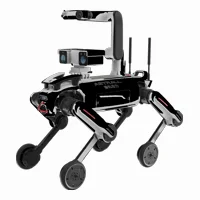
 Astrall Dynamics
ASTRALL Hypertron
Price
Unknown
Type
Quadruped Robots
Status
Unknown
Availability
On sale
Purchase
Not disclosed
Release Date
Jun 22, 2026
Country/Region
China
Last Verified
2026-09-08
50 kg
General Payload
47 kg
Weight
Hypertron is a line of industrial quadruped and wheel-legged robot platforms developed by Astrall Dynamics for power inspection, emergency response, security patrols, and industrial operations. The line combines in-house motors and joint modules with motion control, multi-sensor perception, and modular integration. According to company materials, its models complement one another across routine inspection and heavy-duty work in complex environments.
1 / 1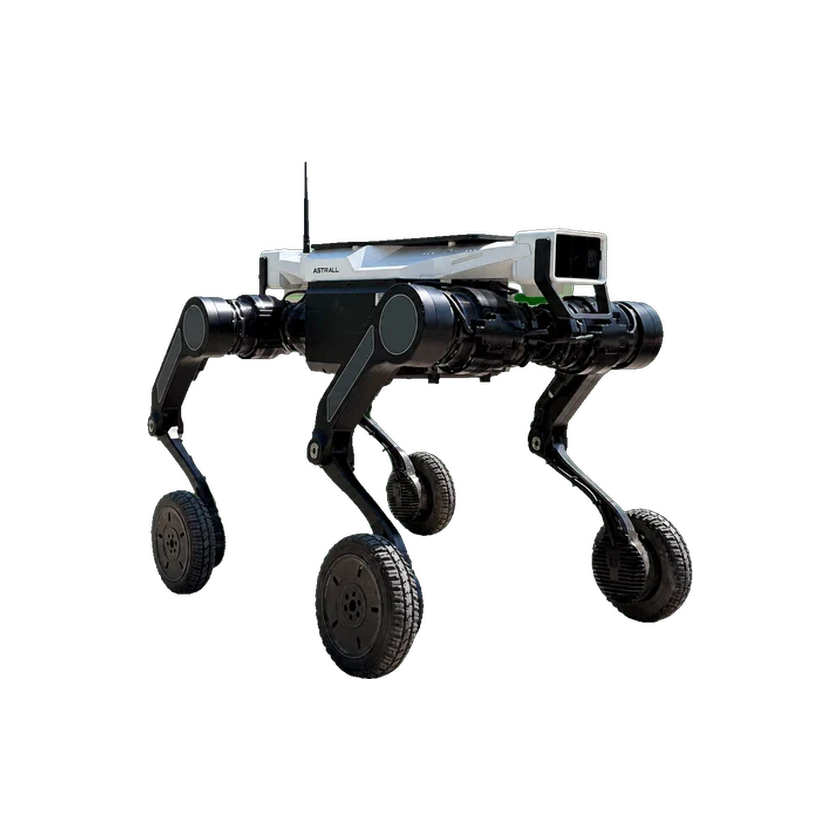
Hardware Specification
Physical Specifications
Ingress Protection (IP)
IP67
Locomotion Type
Wheel-legged quadruped (four legs, each terminating in a driven wheel)
Mobility & Payload
Maximum Grade Angle
45 °
Max Speed
8 m/s
General Payload
50 kg
Standing Load
120 kg
Stair Climbing
25 cm
Obstacle Clearance
100 cm
Continuous Walking Payload
50 kg
Mechanical and mounting
Mounting interface
The Hypertron family is presented with standardized quick-install interfaces for inspection pods, firefighting water cannons, and EOD arms; SW01-specific configuration must be confirmed
Weight
47 kg
Mechanical Structure
Actuator Model
Self-developed high-response, high-precision motors
Sensors
Positioning Module
Centimeter-level continuous positioning in GPS-denied substations and tunnel galleries
Sensors
Self-developed motion-control and perception system
Battery and Runtime
Battery Swap Support
Hot-swappable battery design
Compute Platform
Spatial Foundation Model
Odin1 spatial-memory module is reported as the default spatial-cognition solution
Reliability and environment
Operating temperature
-20–55 °C
Interaction and Communication
Spatial Memory
Semantic spatial memory and real-time mapping in GPS-denied environments
Autonomous Return
Can autonomously return from established spatial memory after task interruption, battery depletion, or communications loss
Sensor Fusion Navigation
LiDAR and IMU fusion navigation.
Development and Expansion
Secondary Development (SDK)
SDK development environment and ROS compatibility.
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Jun 22, 2026
Related Entities
Timeline
- Robot releaseHypertron-SW01
Submit a source or correction