Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not disclosed
Release Date
Unknown
Country/Region
Unknown
Latest parameter verification
2026-11-04
<0.8 kg
Hand weight
5
Finger count

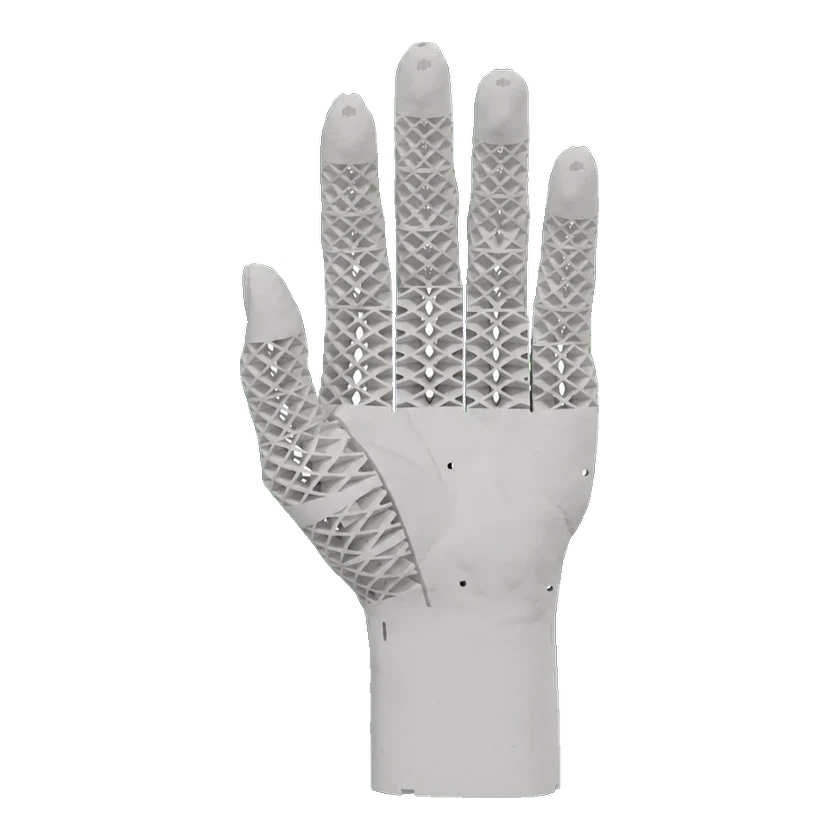
FlexHand V1 is a soft, tendon-driven robotic hand with a compliant lattice structure. The manufacturer brochure reports eighteen DoF without distinguishing active and passive motion, and lists UART, I²C and CAN interfaces in its configuration table.

1 / 1FlexHand V1

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Actuator technology
Tendon-driven
Ingress Protection (IP)
Brochure claims waterproof design; no numerical IP rating provided
Materials
Soft Lattice Structure for intrinsic compliance
Total degrees of freedom
18 DOF
Transmission mechanism
Compact tendon/cable-driven mechanism

Mobility & Payload

Coordination architecture
Multi-finger coordinated control
Hand Payload
Rigid mode: ≤2 kg

Mechanical and mounting

Color
White
Hand weight
<0.8 kg

Strict manufacturer upper bound, converted from less than 800 g; not a measured mass of exactly 0.8 kg.

Mechanical Structure

Dexterous Hand Model
FlexHand V1

Sensors

Sensors
Multimodal sensor integration in modular research design; sensor types not specified

Safety and Protection

Safety System
Structure resists rolling and impact

Interaction and Communication

Communication
UART, I²C and CAN

Development and Expansion

Configuration Options
Research-grade and industrial-grade editions
Integration Interface
Industrial edition designed for plug-and-play, application-specific integration
Operating Modes
Rigid mode used for specified load capacity
Secondary Development (SDK)
Research edition offers an open-source platform for secondary development; API details not specified
Workflow Integration
Flexible automation

Configurations

Manufacturer brochure configuration

Configuration described in the FlexHand V1 brochure, which shows Beta product photos. The interface table does not specify connector pinouts or whether all interfaces are supplied together.

Communication and control

Communication interface
UART

Listed in the manufacturer interface table; simultaneous availability, electrical levels and connector pinouts are not stated.

Communication interface
I²C

Listed in the manufacturer interface table; simultaneous availability, electrical levels and connector pinouts are not stated.

Communication interface
CAN

Listed in the manufacturer interface table; simultaneous availability, electrical levels and connector pinouts are not stated.

Commercial Status

Status
Prototype
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction