
 Unitree Robotics
Dex5-1
Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
On sale
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-12
16 DOF
Active degrees of freedom
20
Mechanical joint count
1.1 kg
Weight
5
Finger count
Unitree Dex5-1P is the alternate product variant listed alongside Dex5-1 on Unitree’s official dexterous-hand product page.
1 / 1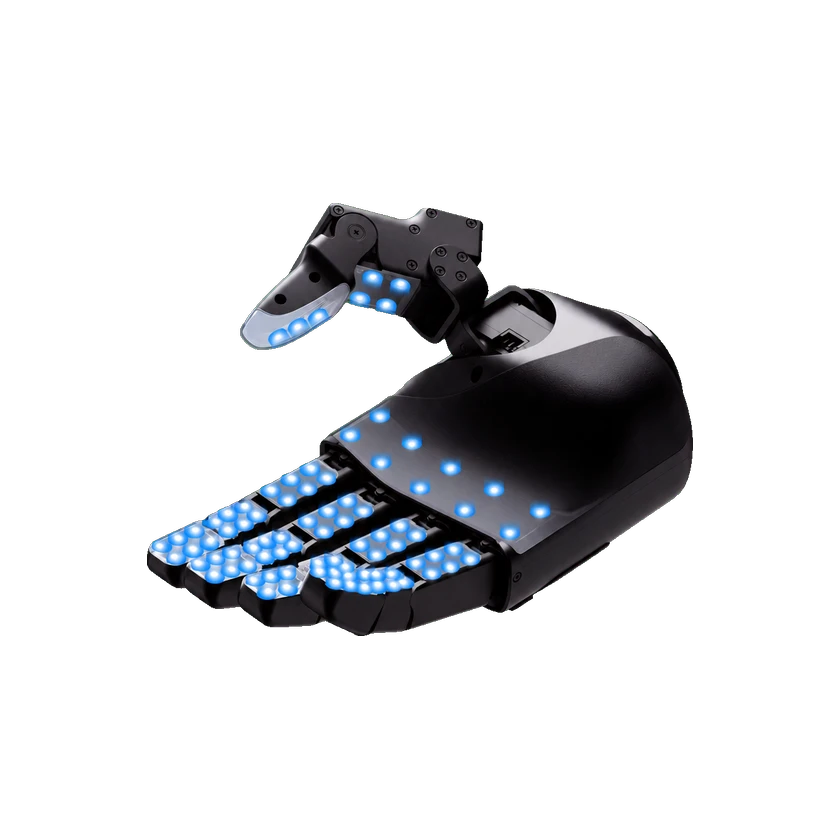
Hardware Specification
Physical Specifications
Active degrees of freedom
16 DOF
Mechanical joint count
20
Dimensions (Standing)
Length, laid flat: 21.73 cm
Dimensions (Standing)
Width, laid flat: 12.75 cm
Dimensions (Standing)
Thickness, laid flat: 7.21 cm
Total degrees of freedom
20 DOF
Mobility & Payload
Hand Payload
Palm left: 4.5 kg
Hand Payload
Palm down: 3.5 kg
General Payload
Mapping withdrawn; see correct parameter
Reach
Mapping withdrawn; minimum grip diameter is a different parameter
Mechanical and mounting
Minimum grip diameter
1 cm
Weight
1.1 kg
Electrical and integration
Dexterous Hand
Five-finger dexterous hand
Joint Name
Thumb joints 0–3; knuckle joints 0–3
Joint Motion Range
thumb joint zero: -33.5–39 °
Joint Motion Range
thumb joint one: 0–100 °
Joint Motion Range
thumb joint two: 0–110 °
Joint Motion Range
thumb joint three: 0–92 °
Joint Motion Range
finger joint zero: -22–22 °
Joint Motion Range
finger joint one: 0–90 °
Joint Motion Range
finger joint two: 0–95 °
Joint Motion Range
finger joint three coupled: 0–81 °
Joint Type
12 micro force-controlled composite transmission joints and 4 micro force-controlled gear joints
Operating voltage
24–60 V
Sensors
Sensors
Joint mode, position, velocity, torque, temperature, voltage, current and IMU feedback; pressure sensor values and temperatures
Battery and Runtime
Battery Voltage
Not disclosed
Max Power
Not disclosed
Power Supply
24 V to 60 V
Performance and tasks
Repeatability
Fingertip: ±1 mm
Reliability and environment
Operating temperature
-20–60 °C
Interaction and Communication
Communication
Full packet: sender 1234 bytes; receiver 1270 bytes
Communication
USB 2.0
Tactile Feedback
Dex5-1P: twelve arrays containing 94 pressure sensors
Development and Expansion
Operating Modes
Joint mode, position, velocity, torque, stiffness coefficient and damping coefficient commands
Commercial Status
Status
Commercial
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “Dex5-1P”
Submit a source or correction