
 DEXROBOT
DexCap
Price
Unknown
Type
Robot Data Collection Systems
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-17
Exoskeleton
Device form factor
Joint angle
Captured data
Arm
Body coverage
Not required
Robot required during capture
A 65-DoF wearable exoskeleton for collecting arm, hand, and waist motion for robotic learning.
1 / 1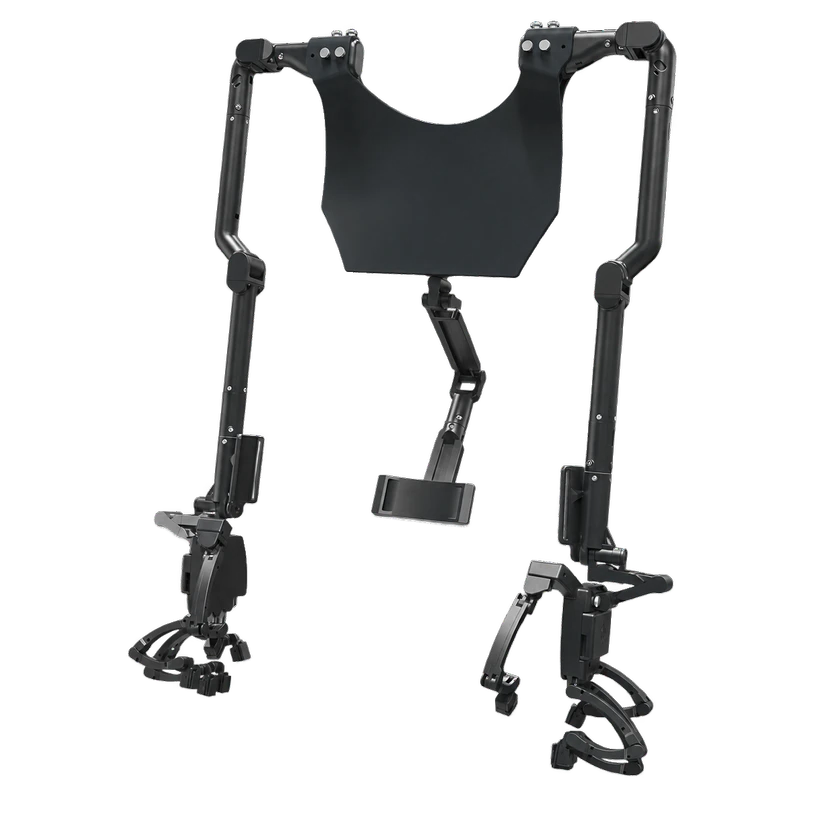
Technical specifications
Setup and calibration
Body coverage
Arm
Body coverage
Wrist
Body coverage
Waist
Body coverage
Fingers
Collection method
Teleoperation
Collection method
Human demonstration
Captured data
Joint angle
Captured data
End-effector pose
External compute required
Required
External tracking required
Depends on configuration
Device form factor
Exoskeleton
Robot required during capture
Not required
Supported robot types
Robot arm
Supported robot types
Dexterous hand
Hardware specifications
Sensing technology
Magnetic encoder
Sensor modules
65 magnetic absolute encoders.
Tracked degrees of freedom
65 DoF: 9 per arm, 21 per hand, and 5 at the waist.
Hardware specifications
Communication frame rate
Wireless communication frame rate: 200 Hz.
Communication frame rate
Wired communication frame rate: 1000 Hz.
Orientation error
End-effector orientation error: roll, pitch, and yaw ≤ 0.1°.
Position error
End-effector position error: X ≤ 0.5 mm, Y ≤ 0.5 mm, Z ≤ 0.1 mm.
Tracked DOF distribution
65 DoF: 9 per arm, 21 per hand, and 5 at the waist.
Connectivity and development
Supported operating systems
Windows / Linux
Mechanical and mounting
Weight
4.2 kg
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Submit a source or correction