Corenetic logoCorenetic

Monte

Monte02

Price
Price not disclosed
Type
Humanoid Robots · Wheeled Humanoid
Applications
Industrial · Manufacturing / Healthcare & Elderly Care · Medical Assistance
Status
Pilot
Availability
Pilot only
Purchase
Not disclosed
Release Date
Aug 8, 2025
Country/Region
China
Last Verified
2026-08-19
21 DOF
Total degrees of freedom
100 kg
Weight
8 h
Runtime

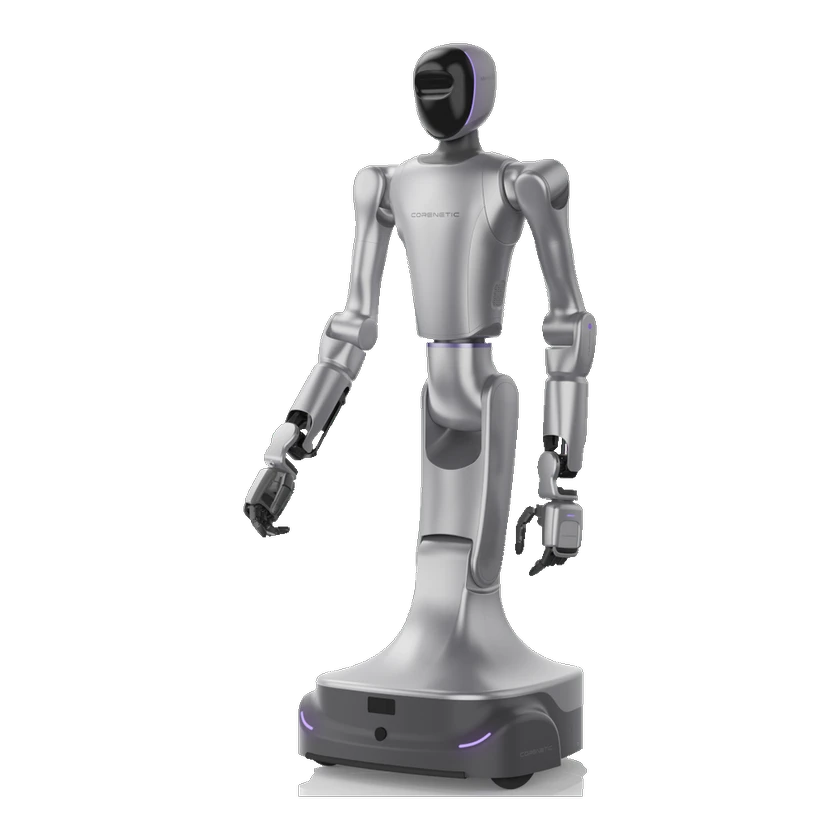
Monte02 is Corenetic’s wheeled humanoid robot for life science, pharmaceuticals, chemicals, and advanced manufacturing. With a differential-drive base, dual 7-DOF arms, and multimodal perception, it supports autonomous navigation, obstacle avoidance, and precise manipulation across multi-device, multi-step industrial workflows.

1 / 1Monte02

Intelligence Profile

Learning ApproachOfficial claim
Human demonstration
Capability Map

MobilityDemonstrated
Navigation

The official Monte02 announcement states that its multi-sensor system enables autonomous navigation and obstacle avoidance in complex environments.

ManipulationDemonstrated
Grasping

The official Monte02 announcement documents a WRC demonstration of precise, flexible sample-preparation operations using multiple end effectors.

ManipulationDemonstrated
Pick and place

The official Monte02 announcement documents sample transfer and equipment loading and unloading in the WRC demonstration.

ManipulationDemonstrated
Tool use

The official Monte02 announcement documents laboratory operations performed through multiple end effectors, including equipment loading and unloading and automated control.

AutonomyDemonstrated
Long-horizon task

The official Monte02 announcement documents a closed-loop, long-sequence laboratory workflow with multiple stages at WRC.

AutonomyDemonstrated
Autonomous operation

The official Monte02 announcement documents robots autonomously completing continuous laboratory operations during the WRC demonstration.

Hardware Specification

Physical Specifications

Arm Length
702 mm per arm
Materials
High-strength magnesium-aluminum alloy frame + ABS engineering plastic shell
Dimensions (Standing)
590 × 619 × 1623 mm (L × W × H)
Total degrees of freedom
21 DOF

Mobility & Payload

Single-arm Payload
6.5 kg per arm at end flange
Chassis Mobility
Two-wheel differential drive
Max Speed
1.0 m/s
Terrain Types
Indoor floors including tile, wood flooring, and plastic flooring

Mechanical and mounting

Controllable DOF per Arm
7 DOF per arm
Head DOF
2 DOF
Waist DOF
3 DOF
Weight
100 kg

Mechanical Structure

Dexterous Hand
Adaptive two-finger gripper or multi-finger dexterous hand; automatic quick change supported

Sensors

Camera
One head RGBD camera and two arm-end RGBD cameras
LiDAR
Equipped; used for autonomous navigation and obstacle avoidance in complex environments
Obstacle Avoidance
LiDAR, ultrasonic, and vision multisensor obstacle avoidance
Ultrasonic Sensor
Equipped; used for autonomous navigation and obstacle avoidance in complex environments
Vision Sensor
RGBD vision: one head camera and two arm-end cameras

Battery and Runtime

Battery Capacity
30 Ah
Battery Type
Lithium-ion battery pack
Battery Voltage
51.2 V
Charging Time
2 h (fast-charge mode)
Runtime
8 h

Compute Platform

AI Compute Claim
200+ TOPS
Onboard Compute
Embedded AI processor, 200+ TOPS
Processor
x86 industrial real-time control board
Software Algorithm
Self-developed spatial-perception and motion-control algorithms

Interaction and Communication

Communication
2.4 GHz / 5 GHz Wi‑Fi 6; Gigabit Ethernet; full-function Type‑C
External Port
Full-function Type-C
Smart Navigation
Map building, real-time positioning, obstacle-avoidance navigation, autonomous recharging

Development and Expansion

Operating Modes
Natural-language and demonstration input

Commercial Status

Status
Pilot
Price
Price not disclosed
Release Date
Aug 8, 2025

Timeline

  1. Robot release
    Monte02
Submit a source or correction