
 Beijing Conco Intelligent Technology Co., Ltd.
Conco Quadruped Inspection Robot
Price
Price not disclosed
Type
Quadruped Robots · Inspection Quadruped
Applications
Industrial · Inspection & Maintenance
Status
Commercial
Availability
Not disclosed
Purchase
Not disclosed
Release Date
2026
Country/Region
China
Last Verified
2026-08-18
30 kg stable payload
General Payload
2–3 h
Runtime
61–62 kg (including battery)
Weight
Conco’s quadruped inspection robot uses configurable point-foot and wheeled-foot modules for autonomous inspection on complex terrain. Official materials list 360° visual perception, autonomous navigation, IP67 protection, automatic return-to-dock charging, visual following, and a 30 kg payload.
1 / 1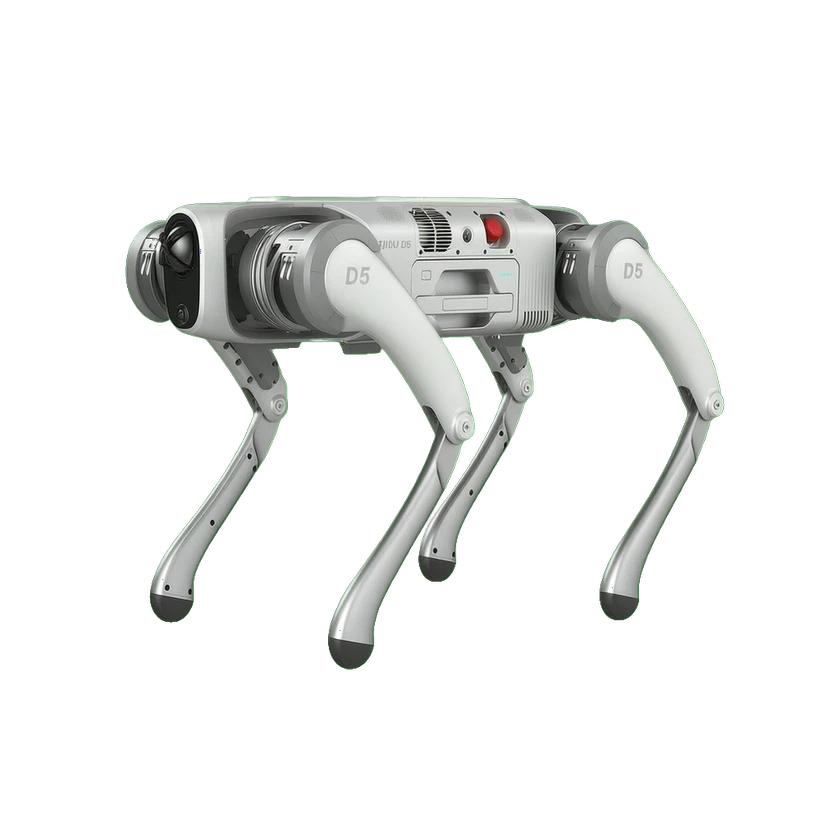
Hardware Specification
Physical Specifications
Ingress Protection (IP)
IP67
Locomotion Type
Point-foot and wheel-foot modes
Mobility & Payload
General Payload
30 kg stable payload
Terrain Types
Forests, mountains, stairs and unstructured terrain
Mechanical and mounting
Weight
61–62 kg (including battery)
Mechanical Structure
Wheel-Leg Swap
Point-foot and wheel-foot modular accessories; sold separately
Sensors
Camera
4 × fisheye cameras
LiDAR
2 × 96-line 3D LiDAR
Obstacle Avoidance
360° visual-fusion perception and dynamic obstacle avoidance
Sensors
2 × 96-line 3D LiDAR + 4 × fisheye cameras
Battery and Runtime
Battery Capacity
1000 Wh
Charging Method
Automatic return-to-dock charging and extra-battery charging supported
Runtime
2–3 h
Compute Platform
Onboard Compute
NVIDIA Jetson Orin AGX 64G + RK3588
Interaction and Communication
Communication
4G + Wi-Fi 6 + Bluetooth
External Port
Expansion interface
Smart Following
Autonomous visual following
Microphone
6-microphone array
Smart Navigation
Autonomous navigation and million-square-metre SLAM map building
Visual Recognition
AI gesture recognition
Visual Tracking
Visual and depth-sensing following
Voice Interaction
AI voice interaction
Commercial Status
Status
Commercial
Price
Price not disclosed
Release Date
2026
Related Entities
Timeline
- Robot releaseConco Quadruped Inspection Robot
Submit a source or correction