Price
Unknown
Type
Quadruped Robots · Heavy-duty Quadruped
Applications
Defense & Security · Defense
Status
Development ended
Availability
Discontinued
Purchase
Not disclosed
Release Date
2005
Country/Region
United States
Last Verified
2026-07-28
150 kg
General Payload
2.5 h (longest reported test)
Runtime
1.6 m/s
Walking Speed
109 kg
Weight

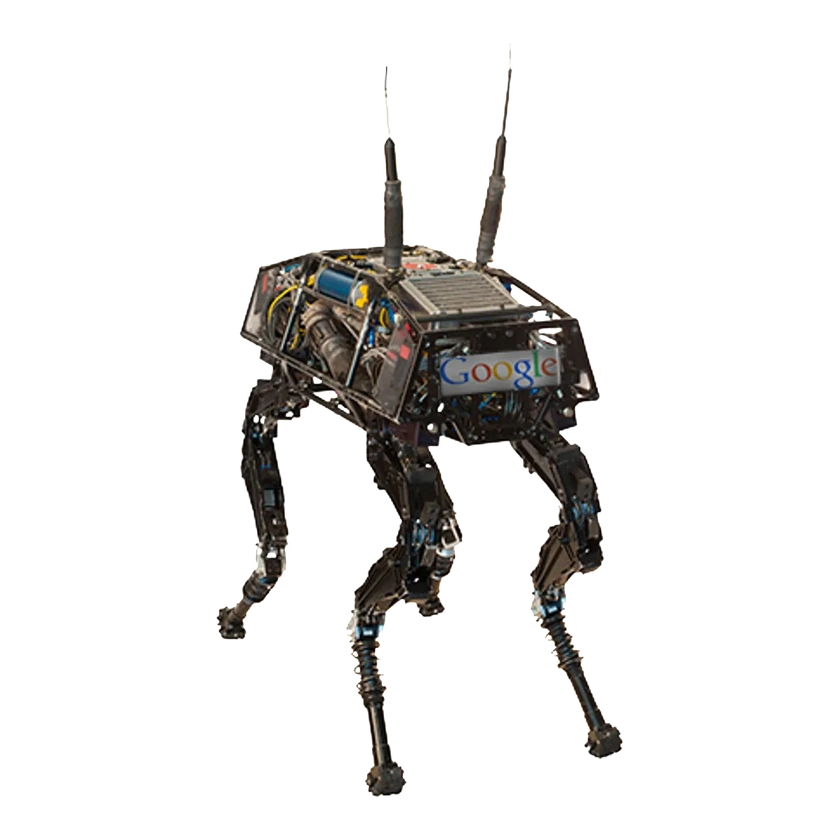
BigDog is Boston Dynamics' rough-terrain quadruped, using hydraulics, sensors and onboard control.

1 / 1BigDog

Capability Map

MobilityDemonstrated
Walking

Boston Dynamics identifies BigDog as its first legged robot to leave the lab and documents rough-terrain navigation.
MobilityDemonstrated
Balance

The official BigDog history entry lists dynamic balancing.

MobilityDemonstrated
Navigation

Boston Dynamics lists rough-terrain navigation for BigDog.

Hardware Specification

Physical Specifications

Locomotion Type
Dynamic quadrupedal locomotion: crawl, trot, running trot and bound
Dimensions (Standing)
1.1 m long × 0.3 m wide × about 1 m tall
Total degrees of freedom
20 DOF

Mobility & Payload

Jumping Capability
Jumped about 1.1 m
Maximum Grade Angle
35° demonstrated; steeper than 45° in simulation
Max Speed
3.1 m/s (7 mph)
General Payload
150 kg
Terrain Types
Rubble, mud, snow, water, rocky terrain and loose scree
Walking Speed
1.6 m/s

Mechanical and mounting

Height
1 m
DOF per Leg
5 per leg: 4 powered joints and 1 passive degree of freedom
Length
1.1 m
Weight
109 kg
Width
0.3 m

Mechanical Structure

Actuator Model
Four low-friction hydraulic actuators per leg
Cooling System
Water-cooled engine, hydraulic-oil heat exchanger and engine radiator
Joint Encoder
Joint position sensors
Joint Type
Low-friction hydraulic cylinders with two-stage servovalves

Sensors

Camera
Stereo camera pair
Foot Force Sensor
Ground-contact and ground-load sensors
Force/Torque Sensor
Joint force sensors
IMU
Inertial sensors for body attitude and acceleration
LiDAR
Integrated LiDAR
Sensors
About 50 sensors covering inertial, joint, ground and internal-state measurements

Battery and Runtime

Power Supply
Water-cooled two-stroke internal-combustion engine, about 15 hp
Runtime
2.5 h (longest reported test)

Compute Platform

Onboard Compute
Onboard computer for locomotion, sensing, control and communications

Interaction and Communication

Communication
IP radios with a remote operator control unit
Smart Navigation
Human-guided navigation; LiDAR following and GPS waypoint tests

Development and Expansion

Operating Modes
Stand, squat, crawl, trot, running trot and bound

Commercial Status

Status
Development ended
Price
Unknown
Release Date
2005

Timeline

  1. Robot release
    BigDog
Submit a source or correction